RoboBin Physical & Fabrication Metrics
Derived geometric properties from 3D tessellation and laser cutting CAM layout for the autonomous mobile waste sorting airframe.
Laser Cutting Profiles & Part Dimension Callouts
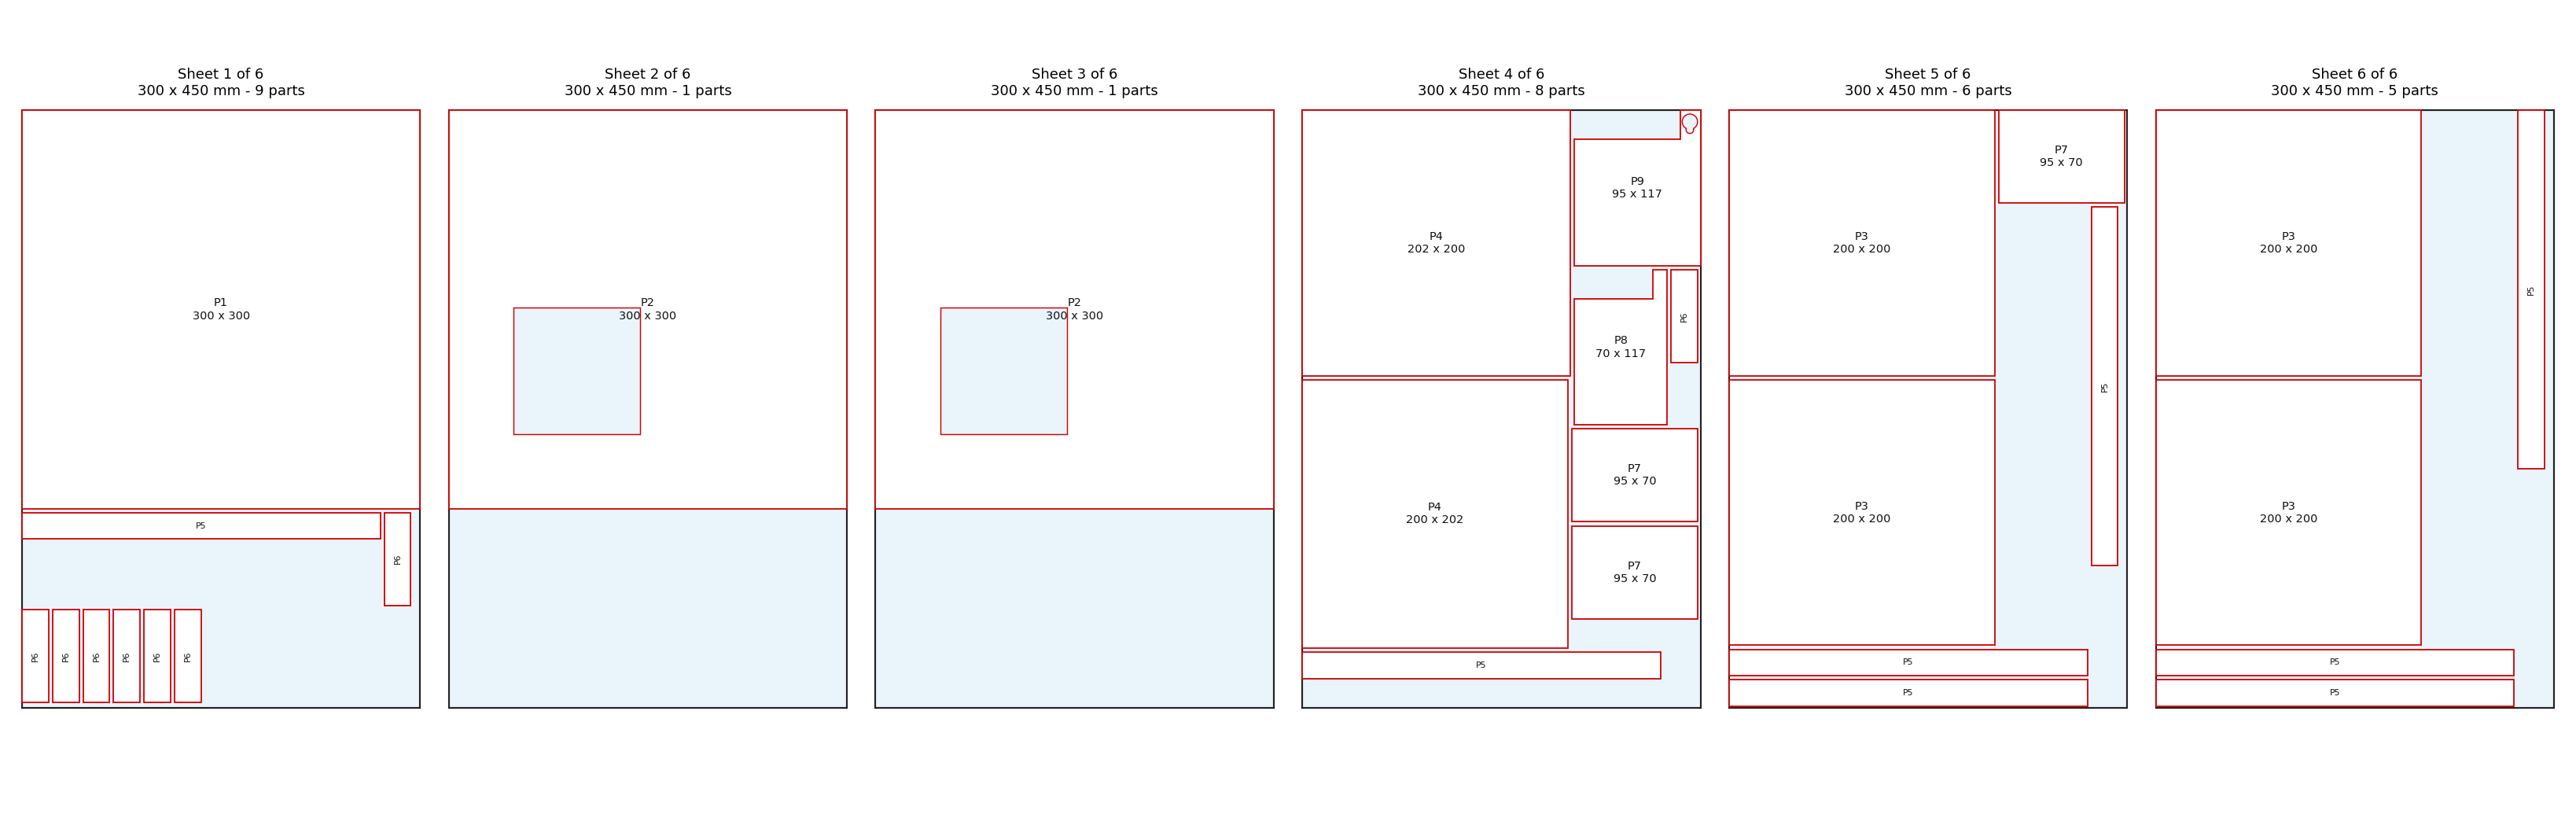
Strictly black and white vector engineering drawings for all 6 acrylic sheets (300 × 450 mm). All part outlines feature annotated dimension callouts. Hover on any part to inspect component telemetry.
Complete 6-Sheet Nesting Plan
Global manufacturing overview showing the 30 components nested across six 300 × 450 mm raw acrylic stock sheets with 3 mm inter-part separation.
Autonomous Hospital AGV Dispatch & Route Simulator
Interactive clinical ward spatial simulator demonstrating autonomous navigation between patient beds, closed-loop MPU6050 turn maneuvers, and real-time UART serial telemetry execution.
4-Quadrant Indexed Rotary Sorter & Hatch Actuation
Interactive mechanical simulation of the internal rotary indexing carousel. The MG995 high-torque servo rotates the internal partition to align the designated quadrant beneath the gravity-drop intake hatch.
Select a test medical waste item to drop into the intake hopper. The system simulates optical beam trigger, AI classification, MG995 indexing, and gravity-drop actuation.
Command Language Protocol & 4-Phase System Roadmap
Unified hardware abstraction layer establishing rigid communication specifications between the embedded Arduino microcontroller and high-level controllers (Android App / Raspberry Pi 3B+).
| Command | Meaning & Function | Sender (Phase 1) | Sender (Phase 3) | Arduino Response |
|---|---|---|---|---|
| F<cm> | Drive forward specified distance (defaults to 300cm in Phase 1) with closed-loop MPU6050 yaw heading stabilization | Android App (BT HC-05) | Raspberry Pi (USB CDC) | DONE\n |
| L / R | Execute sharp 90° orthogonal turn (Left CCW / Right CW) using integrated gyro yaw feedback | Android App (BT HC-05) | Raspberry Pi (USB CDC) | DONE\n |
| X | Emergency Stop: instantly disables H-bridge motor driver outputs and halts ongoing routines | Android App (BT HC-05) | Raspberry Pi (USB CDC) | STOPPED\n |
| B1 – B4 | Run multi-stage sort sequence: rotate carousel drum to section 1–4, open hatch, hold 1.5s, close hatch, return to home | Android App (Manual Test) | Raspberry Pi (Auto AI) | DONE\n |
Core Architectural Rule: In Phase 1, the smartphone sends these ASCII strings over Bluetooth. In Phase 3, the Raspberry Pi 3B+ sends the exact same commands over a USB serial cable. The Arduino firmware remains 100% identical throughout the lifecycle.
- Arduino Uno + Dual DC Motors
- MPU6050 IMU gyro yaw stabilization
- HC-05 with 5V-to-3.3V resistor divider
- Independent motor battery supply
- MG995 metal gear carousel servo
- Secondary hatch trapdoor servo
- Dedicated 5V 3A isolated buck converter
- Calibrated 4-quadrant angles (~60° separation)
- Raspberry Pi 3B+ + Pi Camera
- Quantized MobileNet INT8 TFLite model
- Internal chute LED ring illumination
- Hands-free B1–B4 command dispatch
- Hospital grid layout route planner
- Sequential F / L / R command buffering
- Pi 3B+ Wi-Fi access point bridge
- HC-SR04 ultrasonic collision cutoff